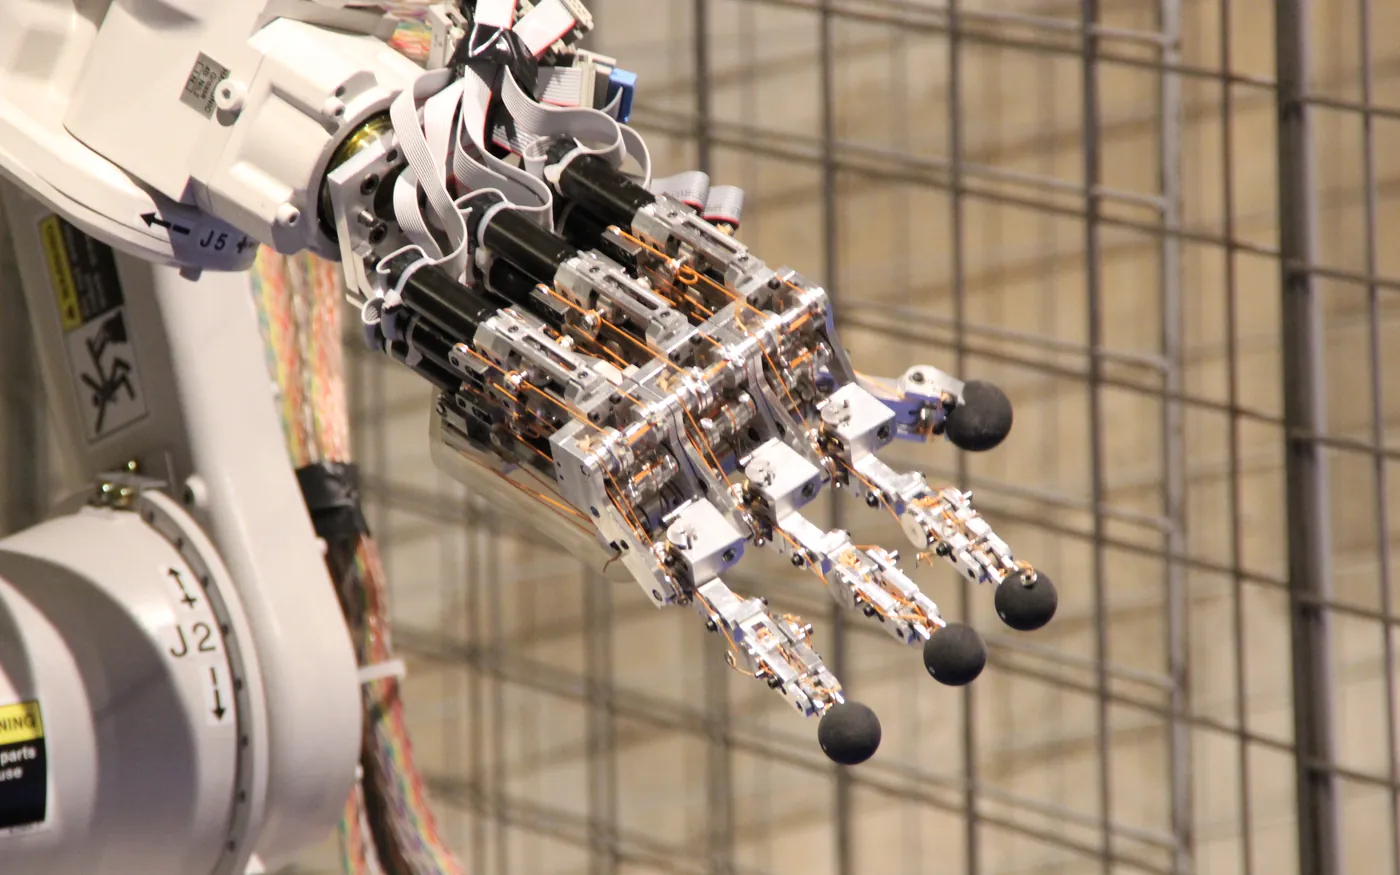
Load your robot, set the task and train it in Isaac Sim, MuJoCo or Gazebo on hosted GPUs, in scenes that match where it will actually work. No CUDA or ROS 2 version fights, and no 16 GB GPU on your desk.
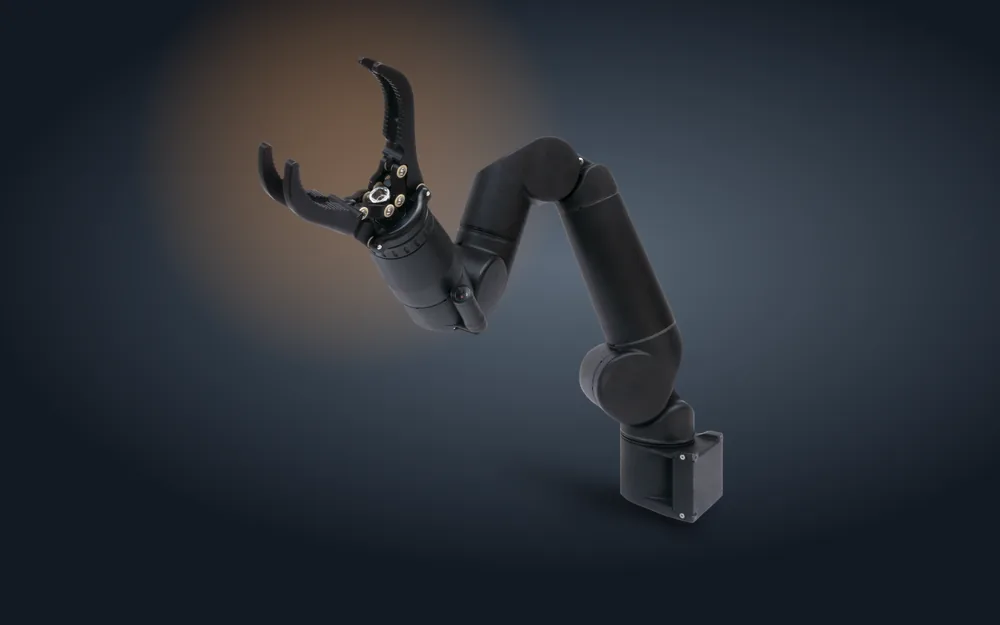
Any Robotarms, quadrupeds, humanoids, drones from URDF3 SimulatorsIsaac Sim, MuJoCo and Gazebo, preconfiguredROS 2the same interfaces as your real robotNo Local GPUruns in the browser on hosted compute
Our mission
Train Tomorrow’s Home Robots in the Homes They’ll Work In.
Homes vary far more than factories, and robots trained in clean, idealised scenes fall apart in real ones. Zain3D captures real homes and makes them simulation-ready, with the objects, physics and robots that next-generation domestic robots need to be trained, tested and evaluated before they reach a real home. Every stage is available through one web platform, SDK and API.
Why simulation work stalls
Most of a Robotics Project Happens Before the First Experiment Runs.
We spoke to researchers training quadrupeds, arms, humanoids and drones. The science was rarely the hard part. Everything around it was.
Setup and Version Drift
CUDA, drivers, Python packages, simulator dependencies and ROS 2 distributions all have to line up before anything runs. Isaac Sim alone can take days.
With Zain3D
Versioned, preconfigured environments. Open one and it runs.
A Compute Ceiling
Isaac Sim wants 16 GB of VRAM or more. Laptops can’t run it, and shared department GPUs crash mid-training. Vision-based training makes it worse.
With Zain3D
Hosted GPUs sized for vision-based training and parallel RL sweeps.
Scenes That Don’t Look Like Reality
Built-in environments are idealised: clean geometry, perfect lighting, no clutter. Policies that work there fall apart on real sensors.
With Zain3D
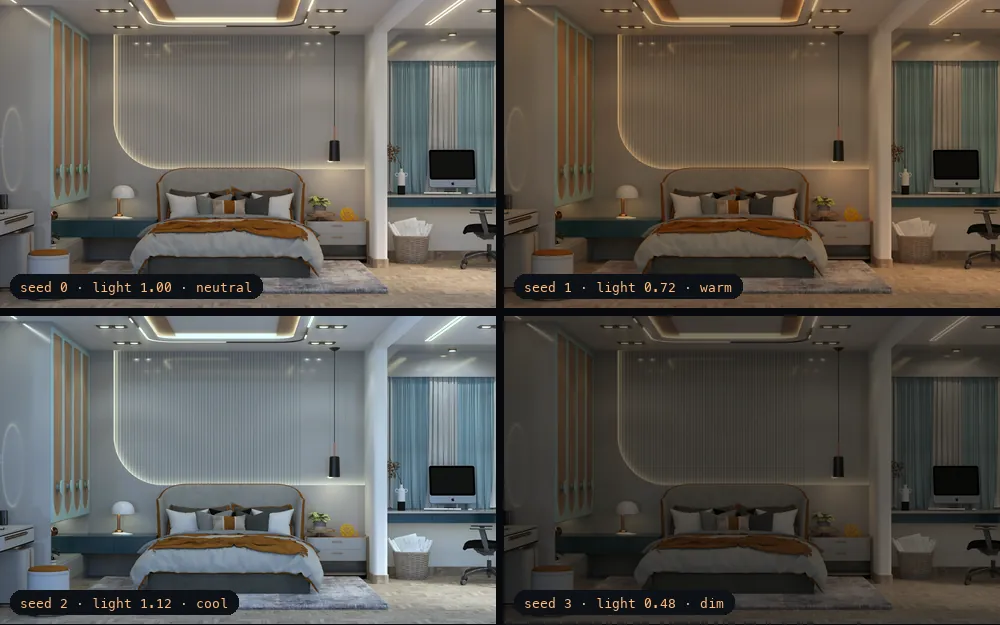
Scenes reconstructed from your real space and objects, at true scale, ready for domain randomisation.
Results That Don’t Reproduce
A setup that works on one workstation fails on the next, and on a co-author’s or reviewer’s machine.
With Zain3D
Every environment is pinned and shareable, so a lab, a class or a reviewer opens exactly the same thing.
A Stack Held Together by Hand
Robot models, controllers, cameras, perception, ROS 2 and data logging live in separate tools with separate setups.
With Zain3D
One workspace, from URDF to logged rollout.
How it works
URDF In. Trained Policy Out.
01
Agent
Import the Embodiment
URDF, MJCF or USD → articulated agent. Kinematic tree, joint limits, actuator models and sensor frames resolved.
02
World
Compose the Scene
Library assets or real-to-sim capture, merged into one scene graph. SI units, collision meshes, PBR materials.
03
Task
Specify the Task
A Markdown spec declares observation and action spaces, reward terms, the success predicate and randomisation ranges.
04
Train
Train and Export
Vectorised RL or VLA post-training on hosted GPUs. Checkpoints export to your ROS 2 stack.
Platforms
One Scene Graph. Three Physics Backends.
The agent and world are authored once as a USD-backed scene graph, then compiled to each backend’s native description: USD for Isaac Sim, MJCF for MuJoCo, SDF for Gazebo. Frames, SI units, inertials and collision geometry stay consistent, so you can swap the solver per experiment without re-authoring assets.
Isaac Sim · Isaac Lab
Perception-Driven Policies
PhysX 5 articulations and RTX-rendered RGB-D, LiDAR and segmentation. Isaac Lab vectorised environments for massively parallel on-policy RL, with sensor noise and appearance randomisation for sim-to-real.
MuJoCo · MJX
Contact-Rich Control at Scale
Convex, soft-constraint contact dynamics with stable, fast stepping. MJX runs batched rollouts on accelerators through JAX, and is differentiable end to end for gradient-based methods.
Gazebo · ROS 2
Hardware-Identical Interfaces
gz-sim bridged over ros_gz, with ros2_control hardware interfaces and MoveIt 2 pipelines matching the physical stack, so controllers deploy with no code changes.
Use cases
What Teams Run on Zain3D.
RL post-training · VLA
Policy Fine-Tuning
Post-train new or existing policies with reinforcement learning. Start from an open VLA such as smolVLA, OpenVLA or π0, or from your own checkpoint, and adapt it to your embodiment, task and scene with shaped rewards, curricula and domain randomisation across thousands of parallel environments. The resulting checkpoint drops back into your stack.
Spatial digital twinSingle-image scene, extended
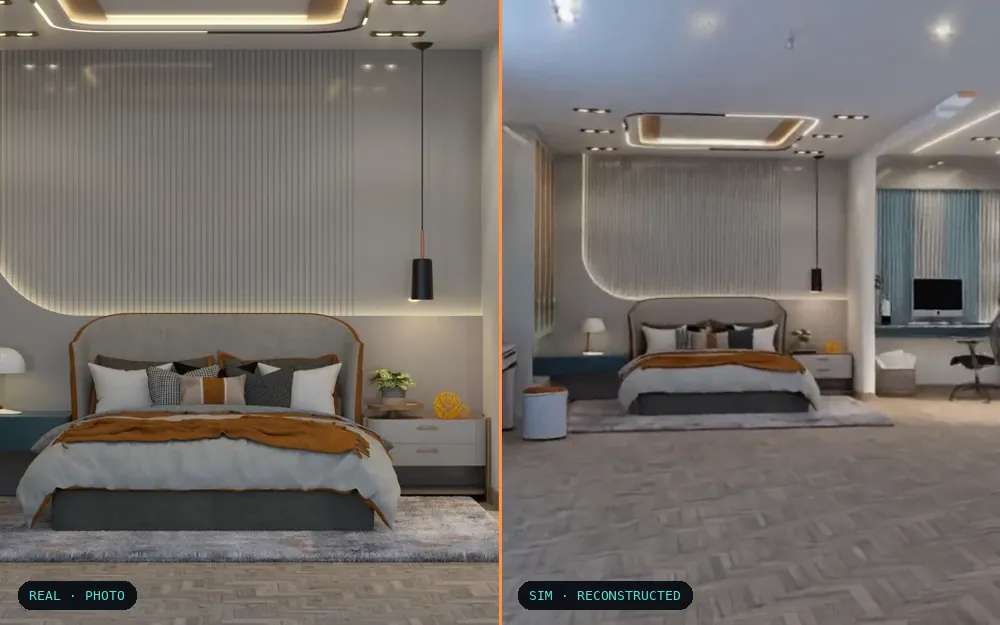
INPUT · 1 photograph
Real-to-sim · images & video
Sim-Ready Replicas
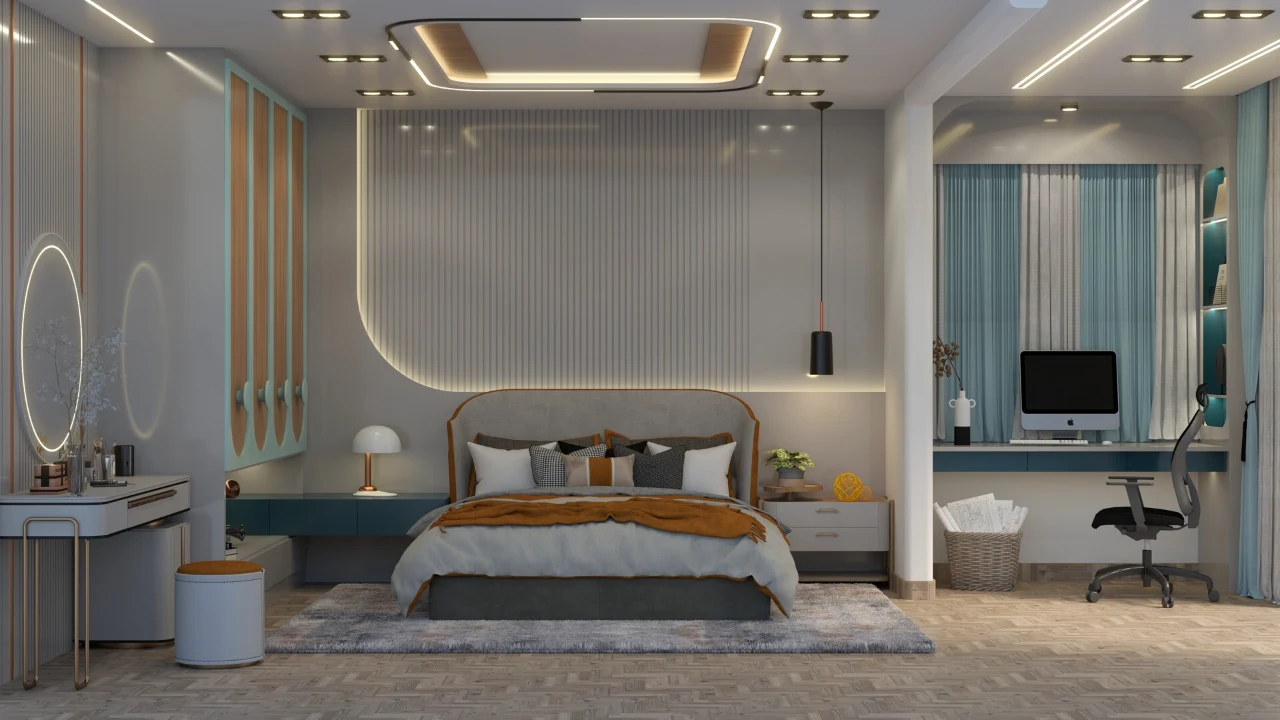
Convert real environments into simulation-ready scenes from images or video. Every object is reconstructed as its own mesh with collision geometry, mass and inertia assigned, and articulated joints on doors, drawers and hinges, then placed at true scale beneath a high-fidelity real-world render. The scene loads straight into Isaac Sim, MuJoCo or Gazebo for robotics, autonomous systems and simulation.
Source
Single image input
Mesh triangles
236,388
Mesh vertices
119,562
Human-in-the-loop
Teleop Training
Train human operators on the skilled control of non-autonomous vehicles, drones and robots. Rehearse gusting wind, low light, sensor dropout and component failure, the conditions too dangerous or expensive to practise for real. Every session is logged, so operator practice doubles as demonstration data for imitation learning.
Safety · alignment · performance
Robot Validation
Validate simulated hardware and AI policies before they touch the real world. Run scenario suites that probe the edges: collisions, joint and torque limits, workspace violations, out-of-distribution scenes and adversarial instructions. Every policy version gets a pass/fail report, failure clips and regression tracking against the last one.
Team
Built by People Who Ship 3D and Vision Systems.
Founder & CEO
Moses Olafenwa
More than a decade building 3D, spatial computing and computer vision. Worked on VR/AR and simulation at Microsoft, hired directly by the inventor of HoloLens. Holds a granted 3D vision patent with Microsoft, wrote an image classifier Bing ran on over a million images, and created ImageAI on GitHub (about 9,000 stars).
Advisor · Strategy and go-to-market
Koye Sodipo
Former Bain and Microsoft, and a two-time founder. Advises Zain3D on strategy and go-to-market.
Bring One Robot and One Task. We’ll Build the Scene With You.
We’re working closely with a small group of labs and robotics teams. Send us your URDF and the task you’re working on.